


Error message
- Can not get file info (nid=, src=TribotBase.png)
- Can not get file info (nid=, src=BluetoothDevices.png)
- Can not get file info (nid=, src=BthDialogOption.png)
- Can not get file info (nid=, src=NXTBoot.png)
- Can not get file info (nid=, src=NXTBluetooth.png)
- Can not get file info (nid=, src=NXTBthSearch.png)
- Can not get file info (nid=, src=NXTBthSearching.png)
- Can not get file info (nid=, src=NXTBthPCfound.png)
- Can not get file info (nid=, src=NXTBthPasskey.png)
- Can not get file info (nid=, src=PCballoon.png)
- Can not get file info (nid=, src=PCConnectComp.png)
- Can not get file info (nid=, src=PCDevlistNXT.png)
- Can not get file info (nid=, src=RtcLink.png)
- Can not get file info (nid=, src=TribotBase.png)
- Can not get file info (nid=, src=BluetoothDevices.png)
- Can not get file info (nid=, src=BthDialogOption.png)
- Can not get file info (nid=, src=NXTBoot.png)
- Can not get file info (nid=, src=NXTBluetooth.png)
- Can not get file info (nid=, src=NXTBthSearch.png)
- Can not get file info (nid=, src=NXTBthSearching.png)
- Can not get file info (nid=, src=NXTBthPCfound.png)
- Can not get file info (nid=, src=NXTBthPasskey.png)
- Can not get file info (nid=, src=PCballoon.png)
- Can not get file info (nid=, src=PCConnectComp.png)
- Can not get file info (nid=, src=PCDevlistNXT.png)
- Can not get file info (nid=, src=TribotBase.png)
- Can not get file info (nid=, src=BluetoothDevices.png)
- Can not get file info (nid=, src=BthDialogOption.png)
- Can not get file info (nid=, src=NXTBoot.png)
- Can not get file info (nid=, src=NXTBluetooth.png)
- Can not get file info (nid=, src=NXTBthSearch.png)
- Can not get file info (nid=, src=NXTBthSearching.png)
- Can not get file info (nid=, src=NXTBthPCfound.png)
- Can not get file info (nid=, src=NXTBthPasskey.png)
- Can not get file info (nid=, src=PCballoon.png)
- Can not get file info (nid=, src=PCConnectComp.png)
- Can not get file info (nid=, src=PCDevlistNXT.png)
- Can not get file info (nid=, src=RtcLink.png)
Aldebaran Robotics "NAO" RTC
RT-Component for controlling a humanoid robot "NAO" (by aldebaran robotics).
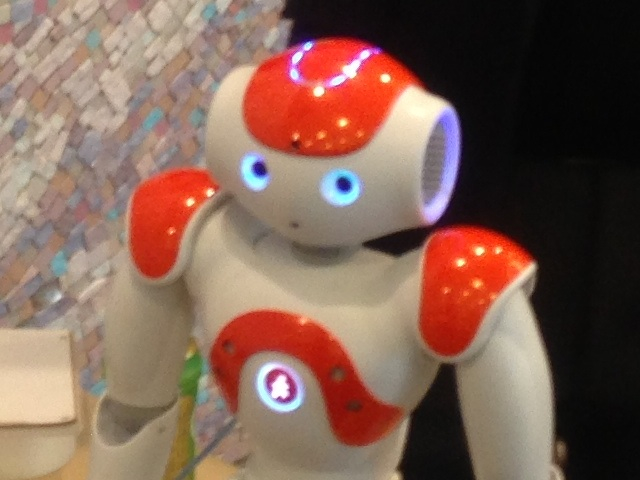
This component allows you :
1. TextToSpeech
2. Motion (Direct Motor Control and Walk)
3. Memory (Sensory data aquisition)
4. Audio
5. Vision
6. Speech Recognition
Launguage : Python
Operating System : Mac, Win, Linux
Depends : pynaoqi 1.14.5, OpenRTM-aist 1.1 Python version.
Still in implementation. Please check this component's official website in Ogata Laboratory's website.