
tutorial (raspberry pi mouse, python, ubuntu, reinforcement month edition)
✏️ Edit this page on GitHub#contents
Introduction
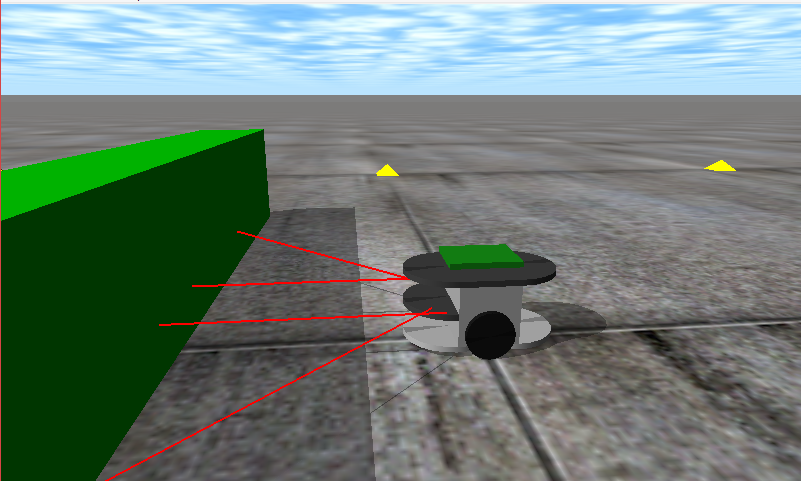
This page explains the procedure for creating a component to control a Raspberry Pi Mouse running in a simulator.
Downloading the Materials
First, download the materials.
git clone https://github.com/OpenRTM/RTM_Tutorial_RaspberryPiMouse_Python
Workshops may sometimes be conducted in environments without Internet access. In that case, the files are included on the distributed USB memory device.
RT Component to Be Created
- RobotController Component
This component connects to the RaspberryPiMouseSimulator component and controls the robot in the simulator.
Creating the RobotController Component
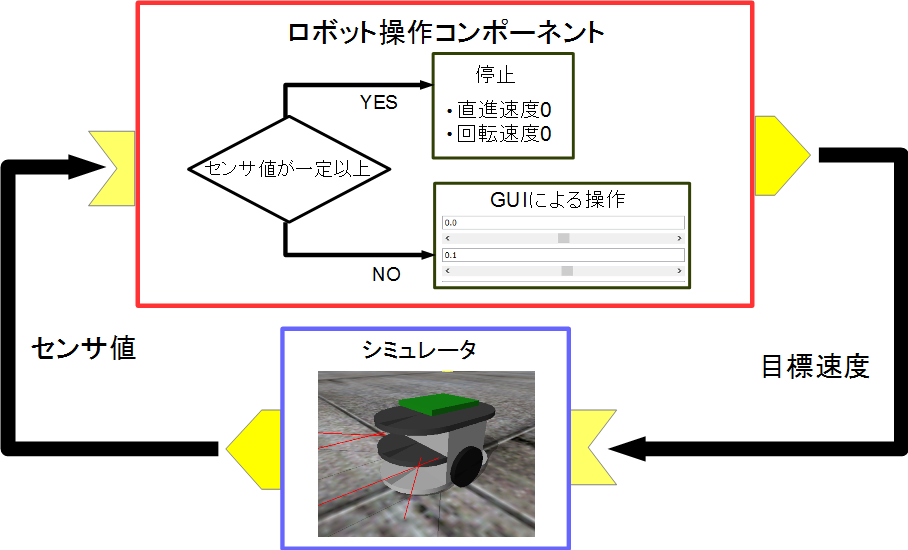
You will create a component that controls the robot in the simulator using a GUI (slider) and automatically stops when a sensor value exceeds a specified threshold.
Creation Procedure
The creation procedure is as follows.
- Verify the development environment
- Define the component specifications
- Generate template source code using RTC Builder
- Edit the source code
- Verify component operation
Operating Environment and Development Environment
A development environment will be set up on Linux (Ubuntu 16.04 is assumed here).
Installing OpenRTM-aist
 $ wget https://raw.githubusercontent.com/OpenRTM/OpenRTM-aist/master/scripts/pkg_install_ubuntu.sh
 $ pkg_install_ubuntu.sh -l all --yes
Installing the JDK
 # For Ubuntu 18.04 and 18.10
 $ sudo apt-get install openjdk-8-jdk
 # For Ubuntu 16.04
 $ sudo apt-get install default-jdk
For Ubuntu 18.04 and 18.10, switch to Java 8 using the following command.
$ sudo update-alternatives --config java
After starting OpenRTP, RTSystemEditor may fail to connect to the Name Server. In that case, add the host name to the localhost entry in /etc/hosts.;
 $ hostname
 ubuntu1804 ← The host name is ubuntu1804
 $ sudo vi /etc/hosts
 127.0.0.1       localhost
 Change it as follows:
 127.0.0.1       localhost ubuntu1804
Installing a Python Editor
Install an editor such as Visual Studio Code or PyDev.
Installing git
$ sudo apt-get install git
Installing cmake
$ sudo apt-get install cmake
Installing Premake and GLUT
These are required to build ODE.
$ sudo apt-get install premake4 freeglut3-dev
RaspberryPiMouseSimulator Component
The simulator component must be built manually.
Run the following commands.
 $ wget https://raw.githubusercontent.com/OpenRTM/RTM_Tutorial/master/script/install_raspimouse_simulator.sh
 $ sudo sh install_raspimouse_simulator.sh
Workshops may sometimes be conducted in environments without Internet access. In that case, run the script included on the distributed USB memory device.
$ sudo sh install_raspimouse_simulator_usb.sh
Component Specifications
RobotController has an OutPort for outputting target velocity, an InPort for receiving sensor values, and configuration parameters for setting the target velocity and the sensor threshold for stopping.
| Component Name | RobotController |
|---|---|
| InPort | |
| Port Name | in |
| Type | TimedShortSeq |
| Description | Sensor values |
| OutPort | |
| Port Name | out |
| Type | TimedVelocity2D |
| Description | Target velocity |
| Configuration | |
| Parameter Name | speed_x |
| Type | double |
| Default Value | 0.0 |
| Constraint | -1.5<x<1.5 |
| Widget | slider |
| Step | 0.01 |
| Description | Forward velocity setting |
| Configuration | |
| Parameter Name | speed_r |
| Type | double |
| Default Value | 0.0 |
| Constraint | -2.0<x<2.0 |
| Widget | slider |
| Step | 0.01 |
| Description | Rotational velocity setting |
| Configuration | |
| Parameter Name | stop_d |
| Type | int |
| Default Value | 30 |
| Description | Sensor value threshold for stopping |
About the TimedVelocity2D Type
The TimedVelocity2D type is used to store the movement velocity of a mobile robot on a two-dimensional plane.
     struct Velocity2D
     {
         /// Velocity along the x axis in metres per second.
         double vx;
         /// Velocity along the y axis in metres per second.
         double vy;
         /// Yaw velocity in radians per second.
         double va;
     };


     struct TimedVelocity2D
     {
         Time tm;
         Velocity2D data;
     };
This data type stores the X-axis velocity vx, Y-axis velocity vy, and rotational velocity around the Z-axis va.
vx, vy, and va represent velocities in the robot-centered coordinate system.
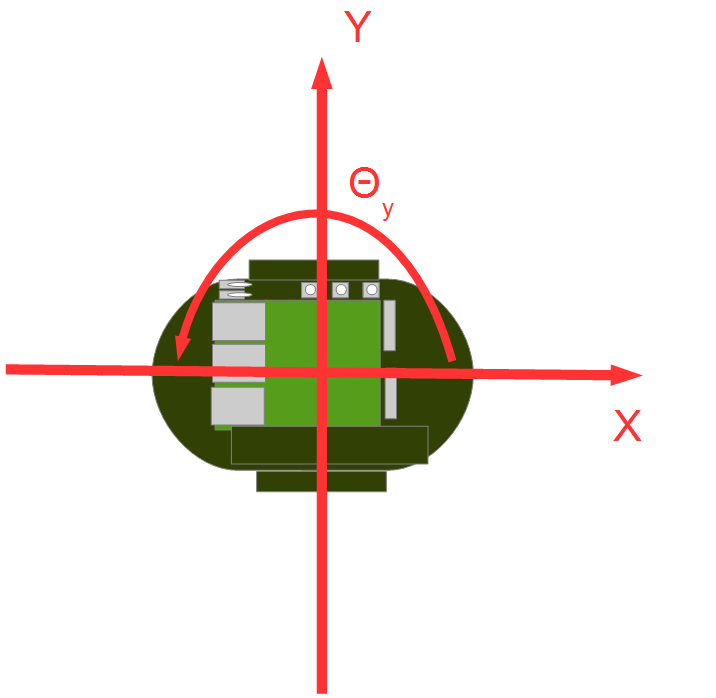
vx is the velocity in the X direction, vy is the velocity in the Y direction, and va is the angular velocity around the Z axis.
For robots such as the Raspberry Pi Mouse, which have two wheels mounted on the left and right sides, vy is assumed to be 0 because lateral slipping is ignored.
The robot is controlled by specifying the forward velocity vx and rotational velocity va.
About Distance Sensor Data
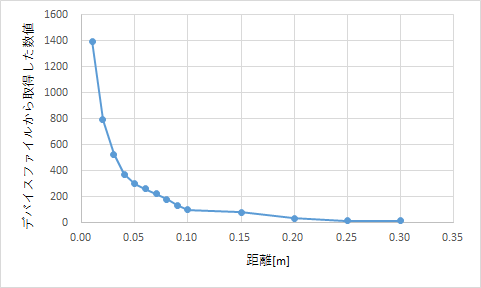
The distance sensor of the Raspberry Pi Mouse outputs larger values as an object gets closer.
| Value Obtained from Device File | Actual Distance [m] |
|---|---|
| 1394 | 0.01 |
| 792 | 0.02 |
| 525 | 0.03 |
| 373 | 0.04 |
| 299 | 0.05 |
| 260 | 0.06 |
| 222 | 0.07 |
| 181 | 0.08 |
| 135 | 0.09 |
| 100 | 0.10 |
| 81 | 0.15 |
| 36 | 0.20 |
| 17 | 0.25 |
| 16 | 0.30 |
The simulator reproduces these values.
The RobotController component implements processing to automatically stop when these values exceed a specified threshold.
Generating Template Code for the RobotController Component
Template code for the RobotController component is generated using RTCBuilder.
Starting RTCBuilder
In Eclipse, the folder used for development work is called a “Workspace,” and in principle all generated files are stored under this folder.
The workspace can be created anywhere as long as it is accessible, but this tutorial assumes the following workspace.
- /home/
/workspace
First, start Eclipse.
Move to the directory where OpenRTP was extracted and enter the following command.
$ ./openrtp
When prompted for the workspace location, specify the workspace described above.
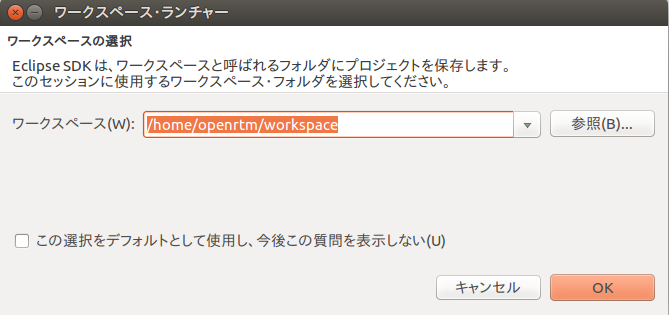
You will then see the following Welcome page.
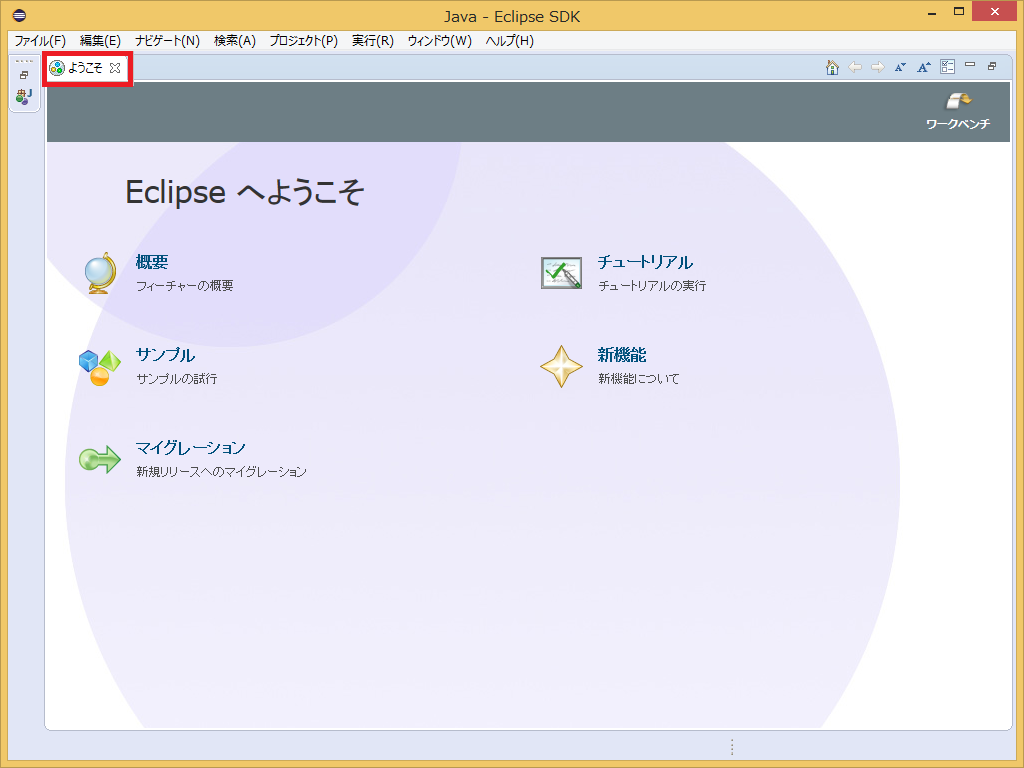
The Welcome page is not needed now, so click the “×” button in the upper-left corner to close it.
Click the [Open Perspective] button in the upper-right corner.
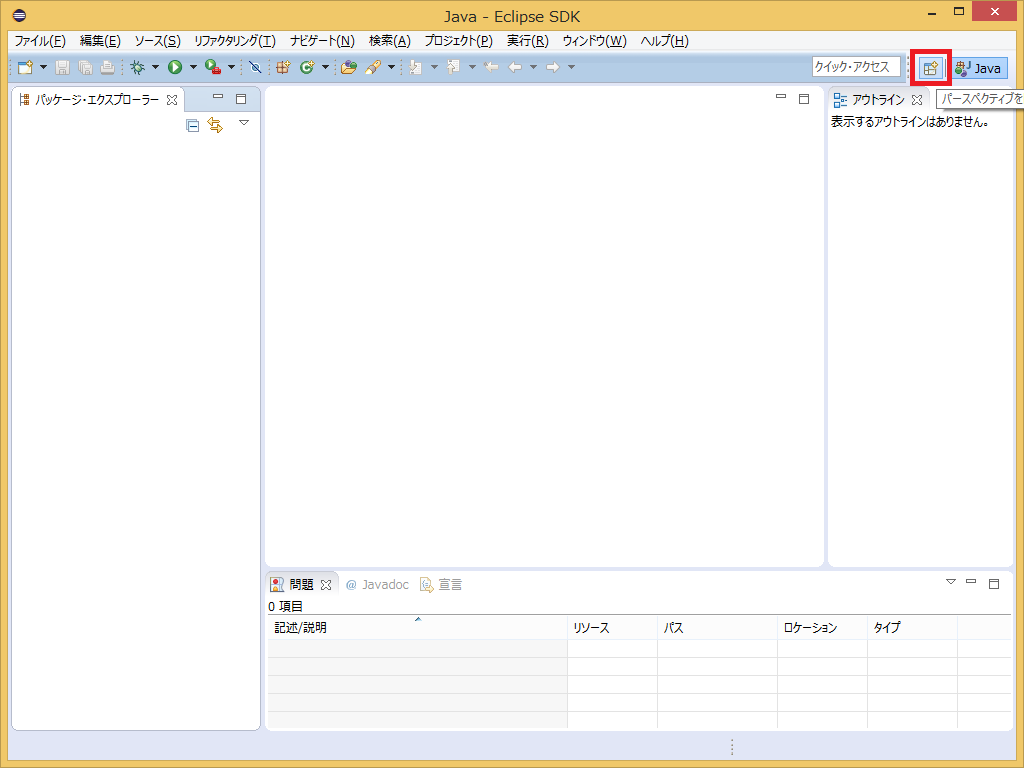
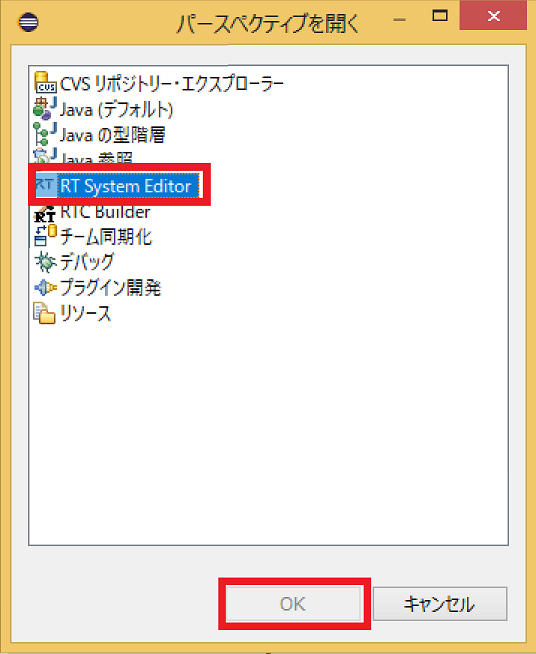
Select “RTC Builder” to start RTCBuilder. The RTCBuilder icon (“Hammer and RT”) will appear in the menu bar.
Creating a New Project
To create the RobotController component, you must first create a new project in RTC Builder.
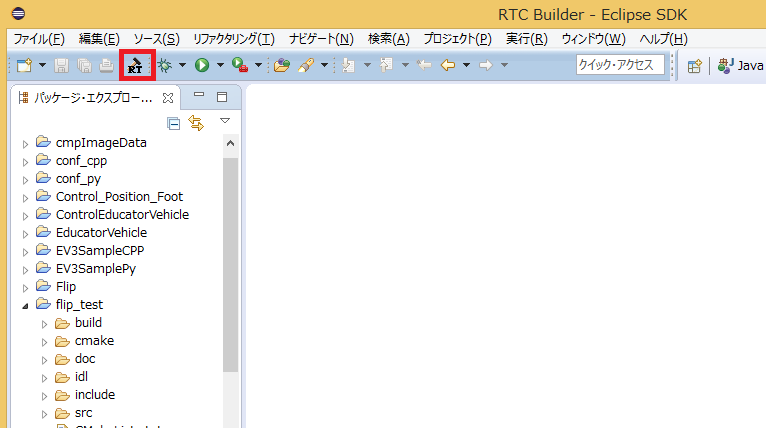
Click the [Open New RTCBuilder Editor] icon in the upper-left corner.
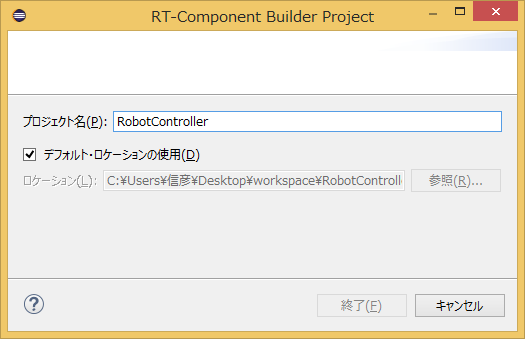
Enter the project name to create (in this example, RobotController) in the “Project Name” field and click [Finish].
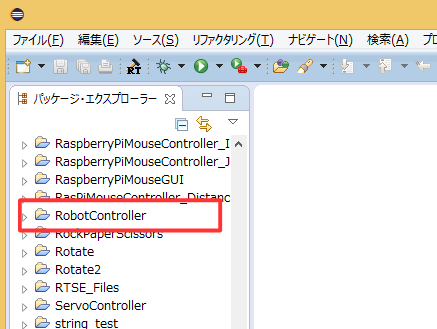
A project with the specified name will be generated and added to the Package Explorer.
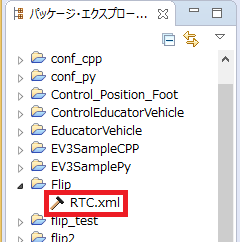
Within the generated project, an RTC profile XML file (RTC.xml) with default values is automatically generated.
Starting the RTC Profile Editor
When RTC.xml is generated, the RTCBuilder editor associated with this project should open automatically in the workspace.
If it does not start, double-click RTC.xml in the Package Explorer.
Entering Profile Information and Generating Code
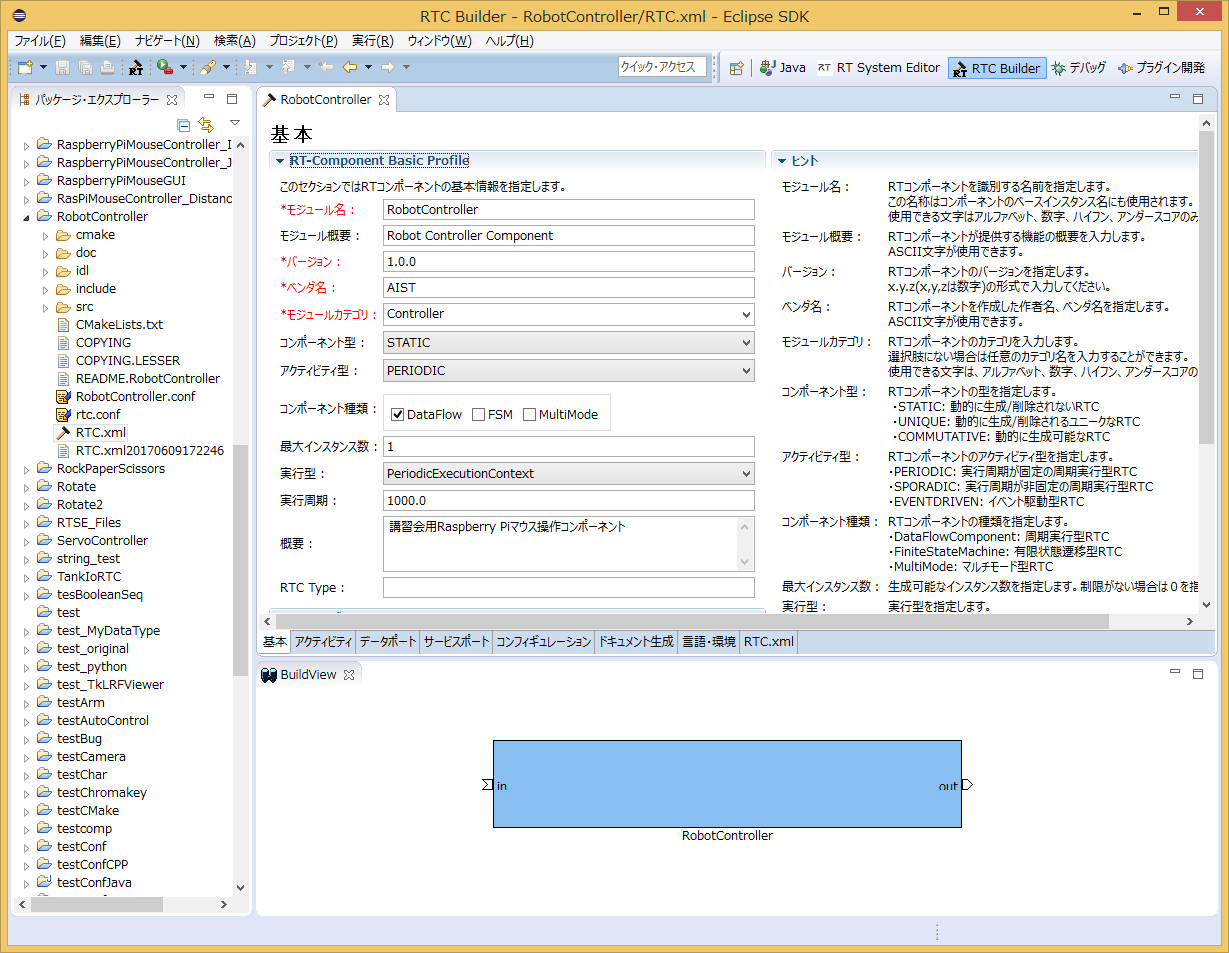
First, select the leftmost “Basic” tab and enter the basic information.
In addition to the RobotController component specification (name) defined earlier, enter the description, version, and other information.
Fields with red labels are required. All other fields can remain at their default values.
- Module Name: RobotController
- Module Description: Optional (Robot Controller component)
- Version: Optional (1.0.0)
- Vendor: Optional
- Module Category: Optional (Controller)
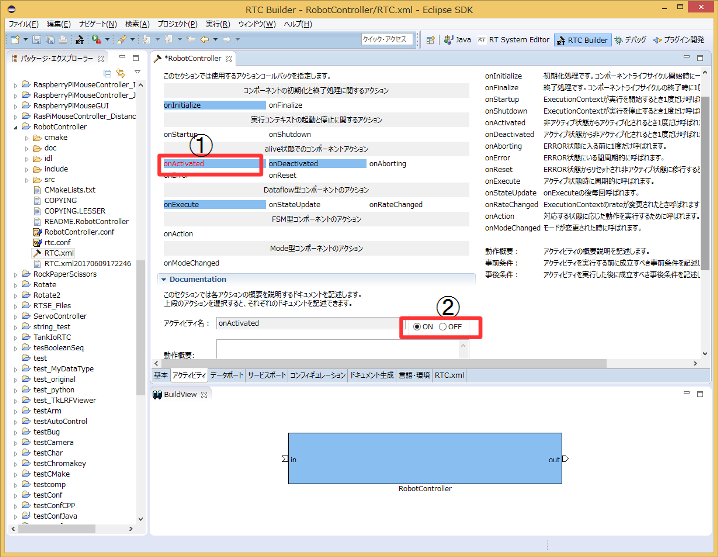
Next, select the “Activity” tab and specify the action callbacks to use.
The RobotController component uses the onActivated(), onDeactivated(), and onExecute() callbacks.
As shown below, click onActivated (①) and then enable it by selecting [ON] with the radio button (②).
Perform the same procedure for onDeactivated and onExecute.
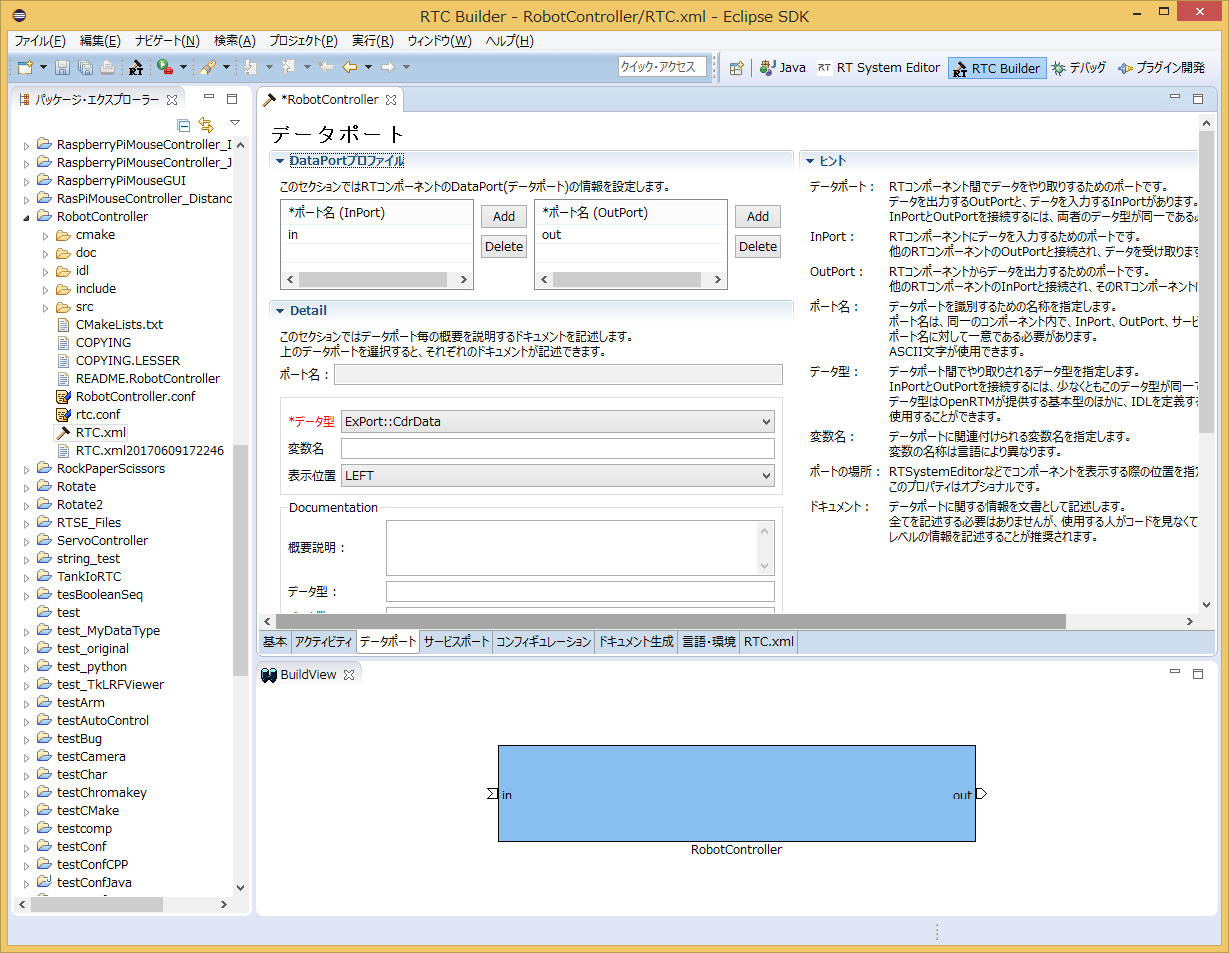
Next, select the “Data Ports” tab and enter the data port information.
Enter the following information based on the specifications defined earlier.
Variable names and display positions are optional and may be left unchanged.
- InPort Profile:
- Port Name: in
- Data Type: TimedShortSeq
- OutPort Profile:
- Port Name: out
- Data Type: TimedVelocity2D
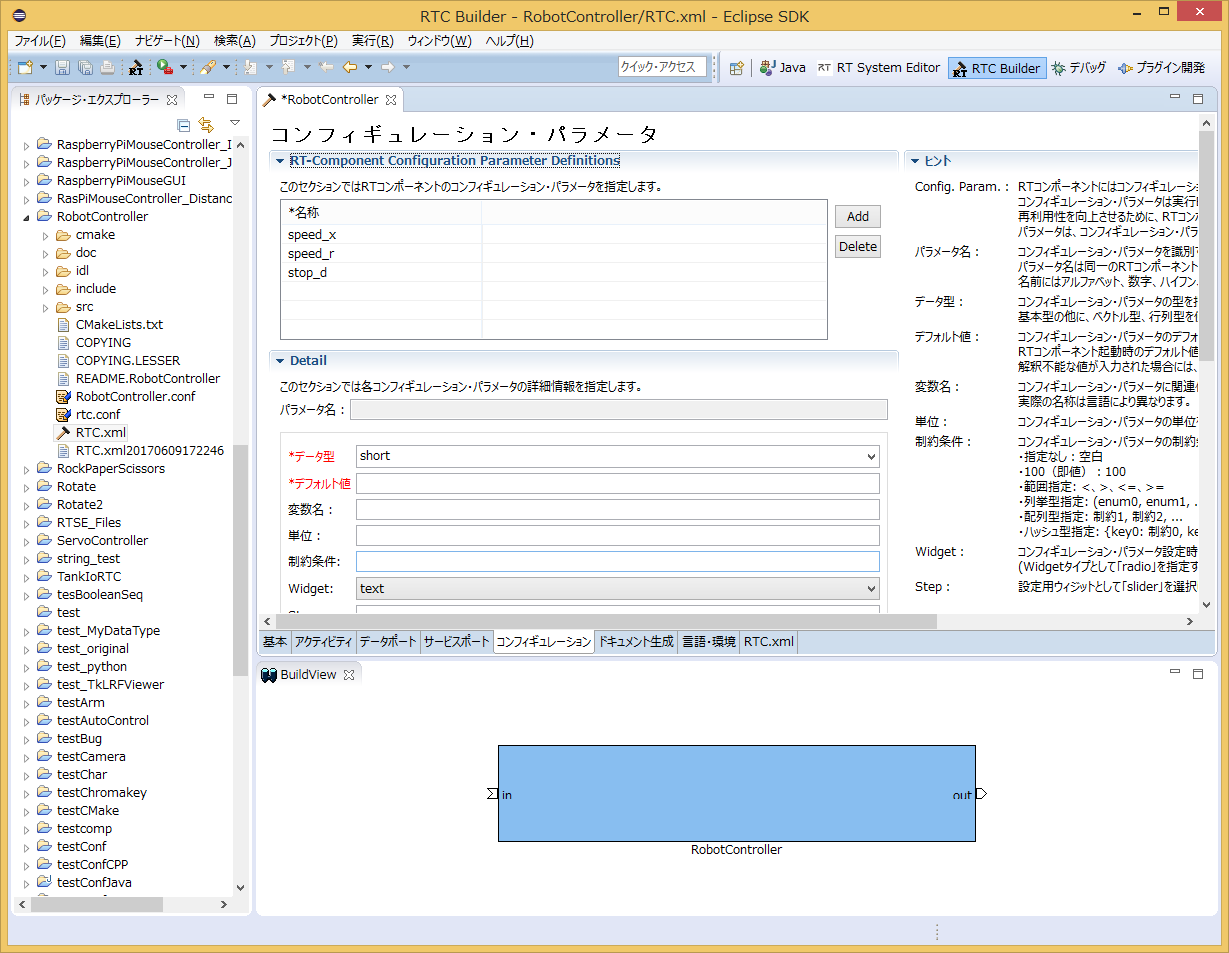
Next, select the “Configuration” tab and enter the Configuration information based on the specifications defined earlier.
Constraint conditions and Widgets are used when displaying component configuration parameters in RTSystemEditor. They provide GUI controls such as sliders, spin buttons, and radio buttons for changing parameter values.
The forward velocity speed_x and rotational velocity speed_r will be controlled using sliders.
- speed_x
- Name: speed_x
- Data Type: double
- Default Value: 0.0
- Constraint: -1.5<x<1.5
- Widget: slider
- Step: 0.01
- speed_r
- Name: speed_r
- Data Type: double
- Default Value: 0.0
- Constraint: -2.0<x<2.0
- Widget: slider
- Step: 0.01
- stop_d
- Name: stop_d
- Data Type: int
- Default Value: 30
- Widget: text
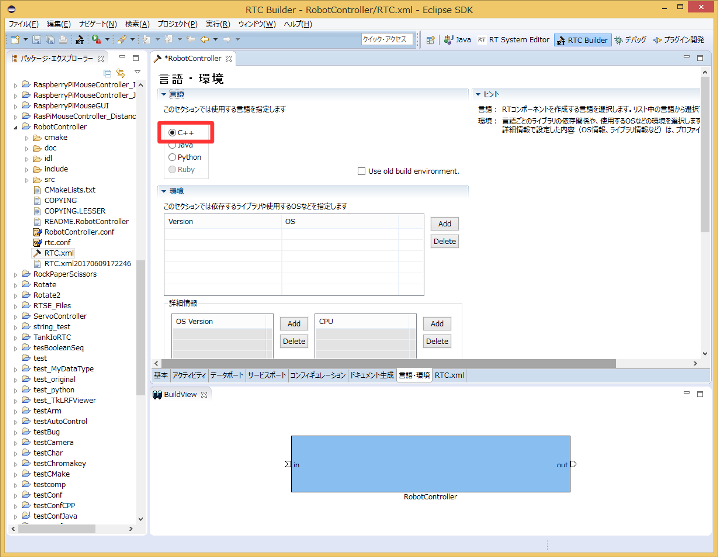
Next, select the “Language / Environment” tab and choose the programming language.
In this tutorial, select C++ as the language.
Note that no default value is set for the language/environment field. If you forget to specify a language, an error will occur during code generation, so be sure to select one.
Finally, click the [Generate Code] button on the “Basic” tab to generate the component template code.
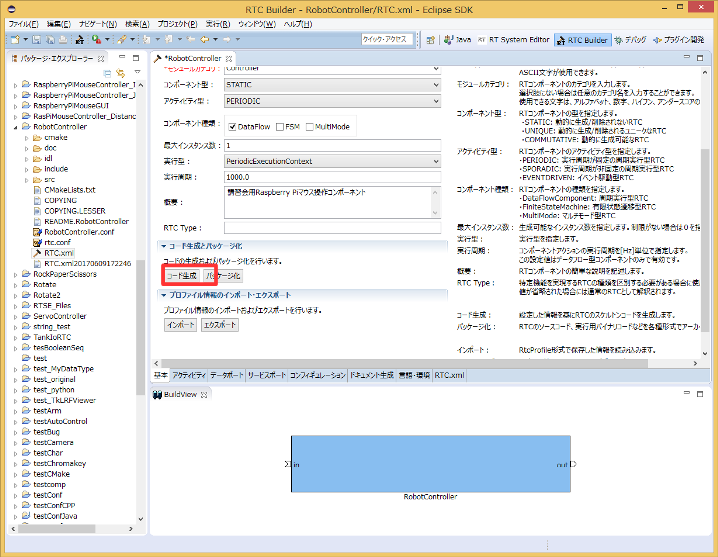
* The generated code files are created in the workspace folder specified when Eclipse was started. The current workspace can be checked from [File] > [Switch Workspace…].
Editing the Source Code
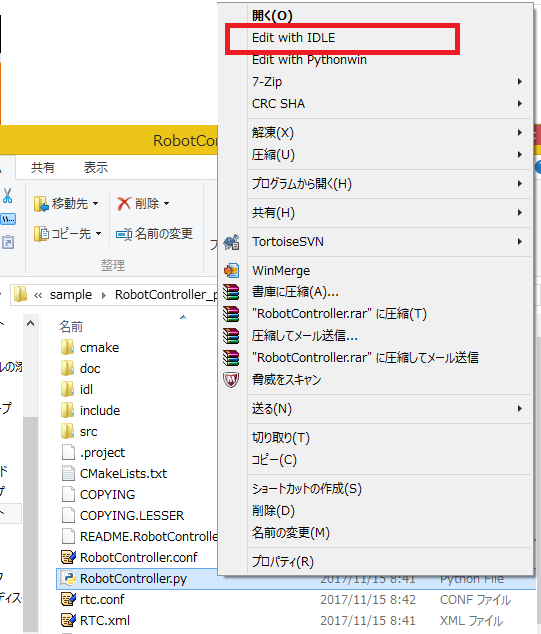
Open and edit <Workspace Directory>/RobotController/RobotController.py using a Python editor.
Modifying Variable Initialization
If you are using RTC Builder from OpenRTM-aist 1.1.2, you must modify the variable initialization section.
(This issue is planned to be fixed in OpenRTM-aist 1.2.0.)
First, modify the initialization of the self._d_in variable in the __init__ function.
 	def __init__(self, manager):
 		OpenRTM_aist.DataFlowComponentBase.__init__(self, manager)

 		#in_arg = [None] * ((len(RTC._d_TimedShortSeq) - 4) / 2) ← Delete
 		#self._d_in = RTC.TimedShortSeq(*in_arg) ← Delete
 		#Add the following line
 		self._d_in = RTC.TimedShortSeq(RTC.Time(0,0),[])
Next, modify the initialization of the self._d_out variable.
 		#out_arg = [None] * ((len(RTC._d_TimedVelocity2D) - 4) / 2) ← Delete
 		#self._d_out = RTC.TimedVelocity2D(*out_arg) ← Delete
 		#Add the following line
 		self._d_out = RTC.TimedVelocity2D(RTC.Time(0,0),RTC.Velocity2D(0.0,0.0,0.0))
This completes the modification.
Implementing Activity Processing
In the RobotController component, the configuration parameters (speed_x, speed_y) are controlled using sliders, and their values are output from the OutPort (out) as the target velocity.
Values input through the InPort (in) are stored in a variable, and the robot stops when the value exceeds a specified threshold.
The processing performed in onActivated(), onExecute(), and onDeactivated() is shown below.
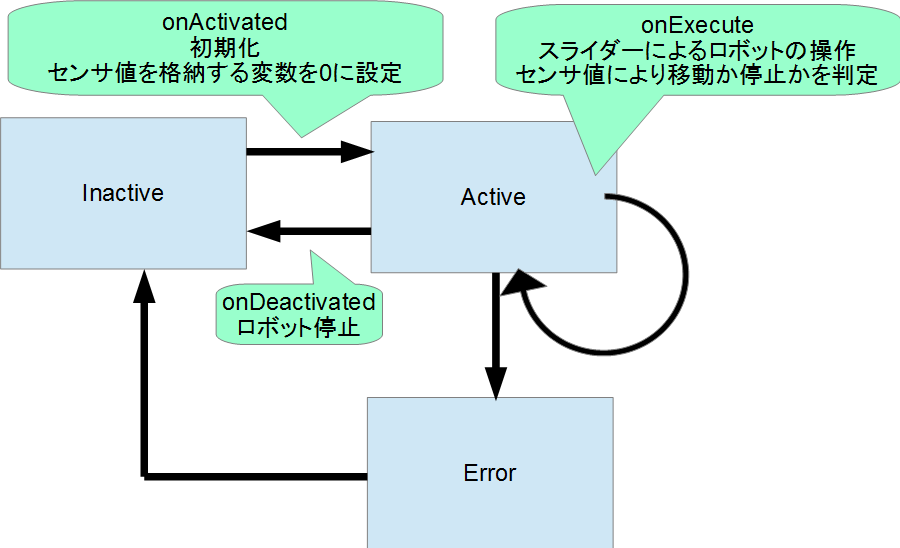
Implement onActivated(), onDeactivated(), and onExecute() as shown below.
 	def onActivated(self, ec_id):
 		#センサー値初期化
 		self.sensor_data = [0,0,0,0]
 		return RTC.RTC_OK
 	def onDeactivated(self, ec_id):
 		#ロボットを停止する
 		self._d_out.data.vx = 0
 		self._d_out.data.va = 0
 		self._outOut.write()
 		return RTC.RTC_OK
 	def onExecute(self, ec_id):
 		#入力データの存在確認
 		if self._inIn.isNew():
 			data = self._inIn.read()
 			#この時点で入力データがm_inに格納される
 			#入力データを別変数に格納
 			self.sensor_data = data.data[:]
 		#前進するときのみ停止するかを判定
 		if self._speed_x[0] > 0:
 			for d in self.sensor_data:
 				#センサ値が設定値以上か判定
 				if d > self._stop_d[0]:
 					#センサ値が設定値以上の場合は停止
 					self._d_out.data.vx = 0
 					self._d_out.data.va = 0
 					self._outOut.write()
 					return RTC.RTC_OK

 		#設定値以上の値のセンサが無い場合はコンフィギュレーションパラメータの値で操作
 		self._d_out.data.vx = self._speed_x[0]
 		self._d_out.data.va = self._speed_r[0]
 		self._outOut.write()

 		return RTC.RTC_OK
Verifying Operation of the RobotController Component
Connect the created RobotController to the simulator component and verify its operation.
Download the RaspberryPiMouseSimulator component from the following location.
Workshops may sometimes be conducted in environments without Internet access. In that case, the files are included on the distributed USB memory device.
Starting NameService
Start the Name Service used to register component references.
$ rtm-naming
Starting the RobotController Component
Start the RobotController component.
Execute the RobotControllerComp file in the RobotController\build\src folder.
$ RobotControllerComp
Starting the Simulator Component
Move to the directory where the RaspberryPiMouseSimulator component was installed and start it using the following command.
$ src/RaspberryPiMouseSimulatorComp
Connecting the Components
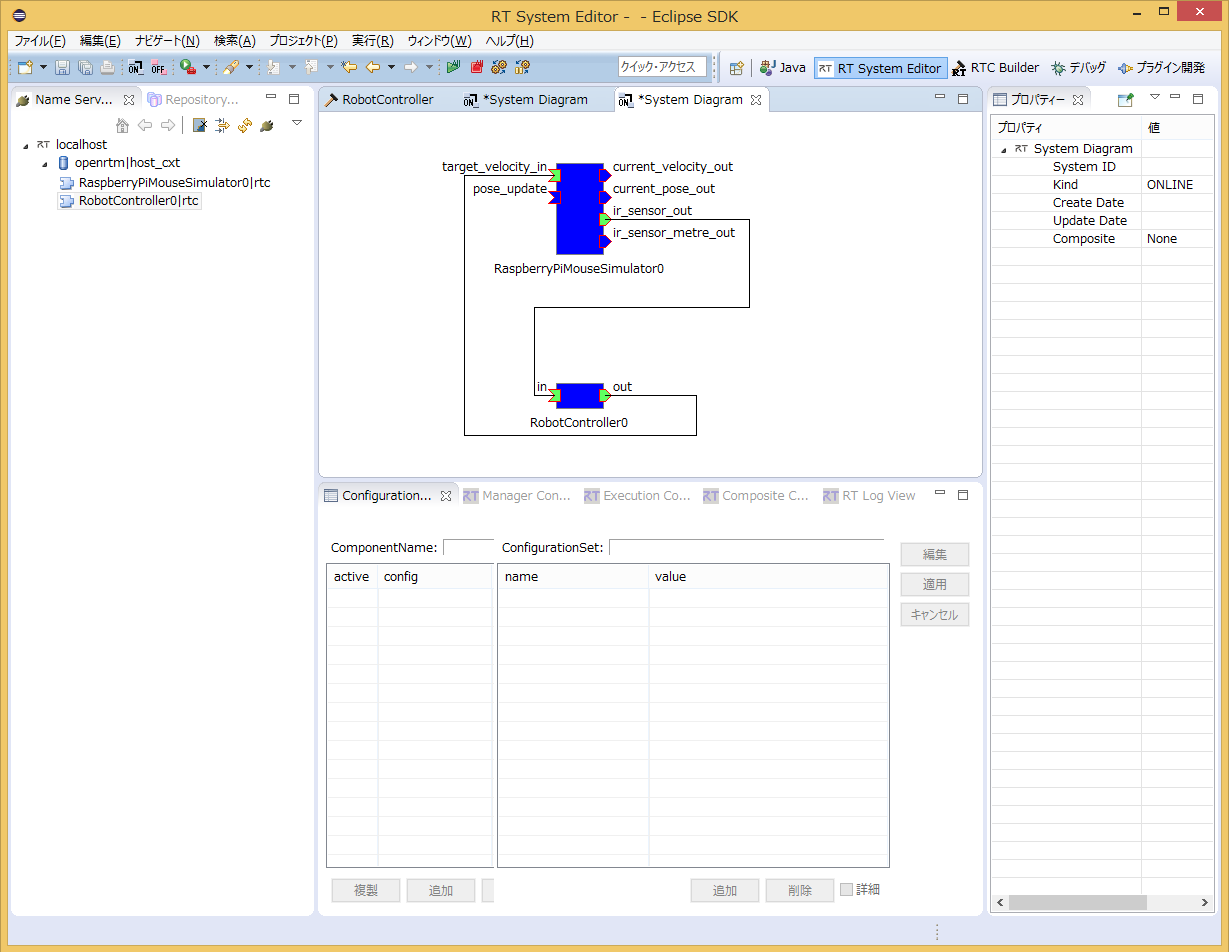
In RTSystemEditor, connect the RobotController component and RaspberryPiMouseSimulator component as shown below.
Activating the Components
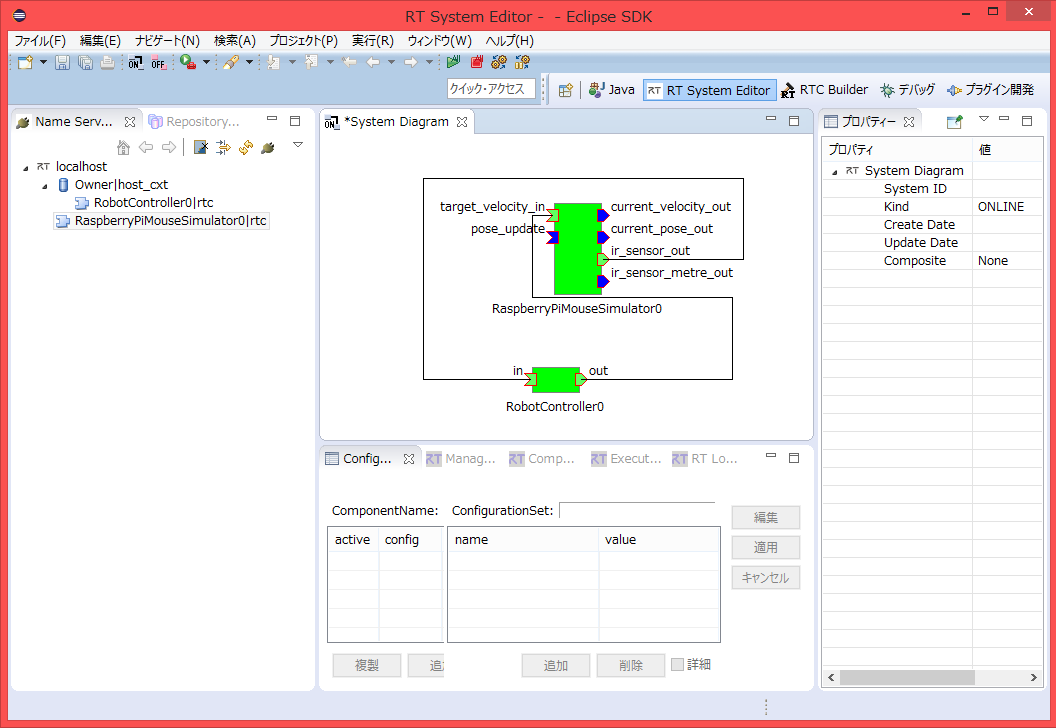
Click the [All Activate] icon at the top of RTSystemEditor to activate all components.
If activation succeeds, the components are displayed in yellow-green as shown below.
Operation Check
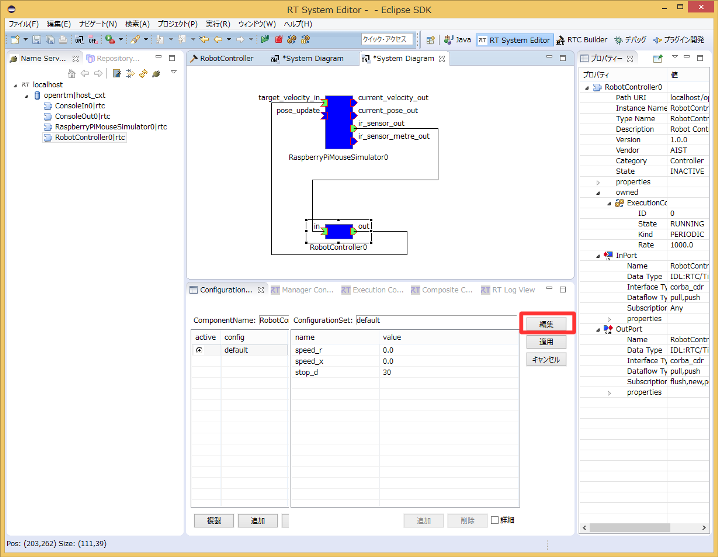
As shown below, you can change the configuration from the [Edit] button in the Configuration View.
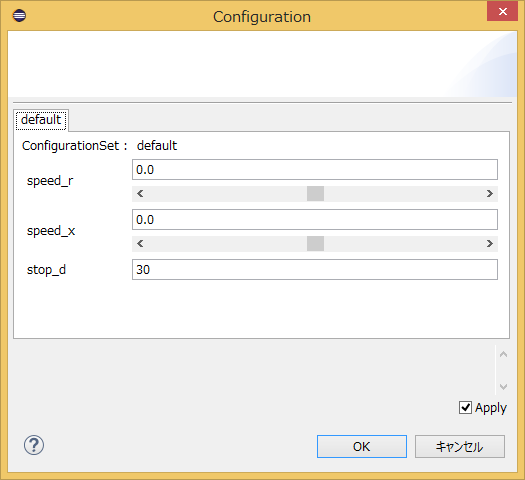
Operate the sliders and verify that the [Raspberry Pi] Mouse in the simulator can be controlled.
Operation Check on the Actual Robot
If an actual Raspberry Pi Mouse is available in the workshop, you can verify operation on the real robot.
The procedure is as follows.
- Turn on the Raspberry Pi Mouse
- Connect to the Raspberry Pi Mouse access point
- Connect the ports
- Activate the components
Turning On the Power
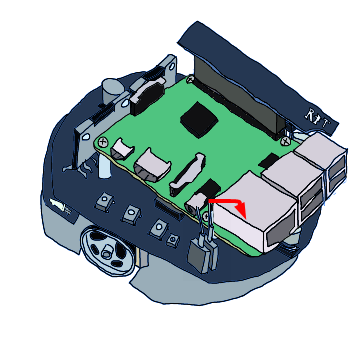
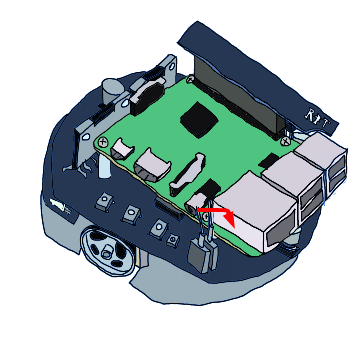
The Raspberry Pi Mouse has two power switches: one for the Raspberry Pi and one for the motors.
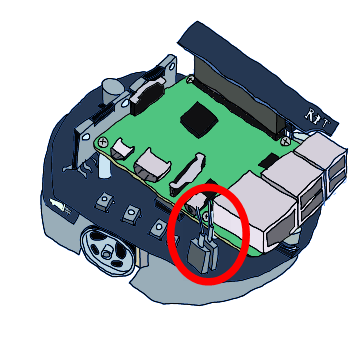
Turning on the inner power switch starts the Raspberry Pi.
Turning Off the Power
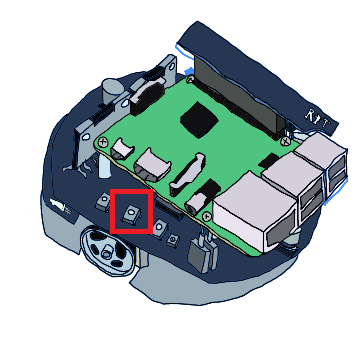
When turning off the Raspberry Pi, do not turn it off directly using the power switch.
Press and hold the center button among the three aligned buttons for a few seconds to start shutdown.
After Raspbian has completely shut down in approximately 10 seconds, turn off the power switch.
Connecting to the Access Point
Refer to the following pages for instructions on connecting to a wireless access point.
The SSID and password are written on the label attached to the Raspberry Pi Mouse.
First, click the network icon in the lower-right corner.

Next, select raspberrypi_*** from the list.

Enter the password.

When the network is switched, component registration with the Name Server and port connections may fail. Therefore, exit OpenRTP, the Name Server, and all components once.
If they were started after switching the network, there is no problem and you do not need to restart them.
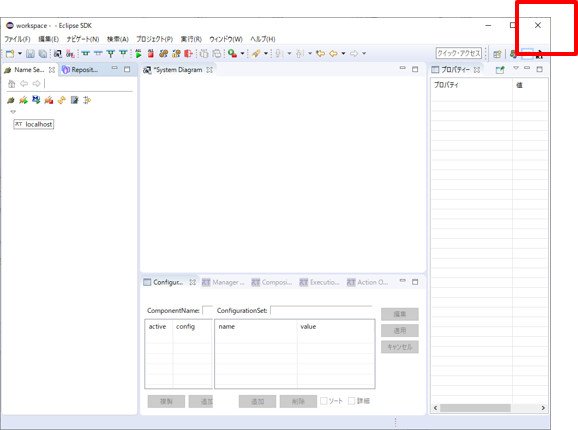
To exit OpenRTP, click the × button in the upper-right corner. When asked whether to save the system diagram, select “Don’t Save.”
Start OpenRTP by double-clicking the desktop shortcut.
To restart the Name Server in RT System Editor, click the “Start Name Service” button again.
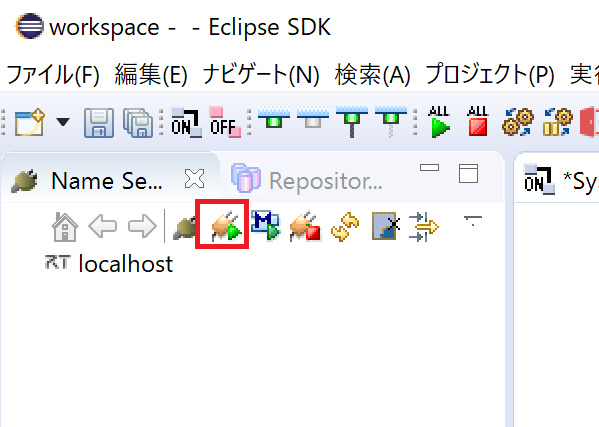
Starting the Name Server and RTC on Raspberry Pi
This step is required only for the following Raspberry Pi Mouse with LiDAR. If you are using a Raspberry Pi Mouse without LiDAR, proceed to the next step.

Access 192.168.11.1 using a web browser such as Edge, Chrome, or Firefox.
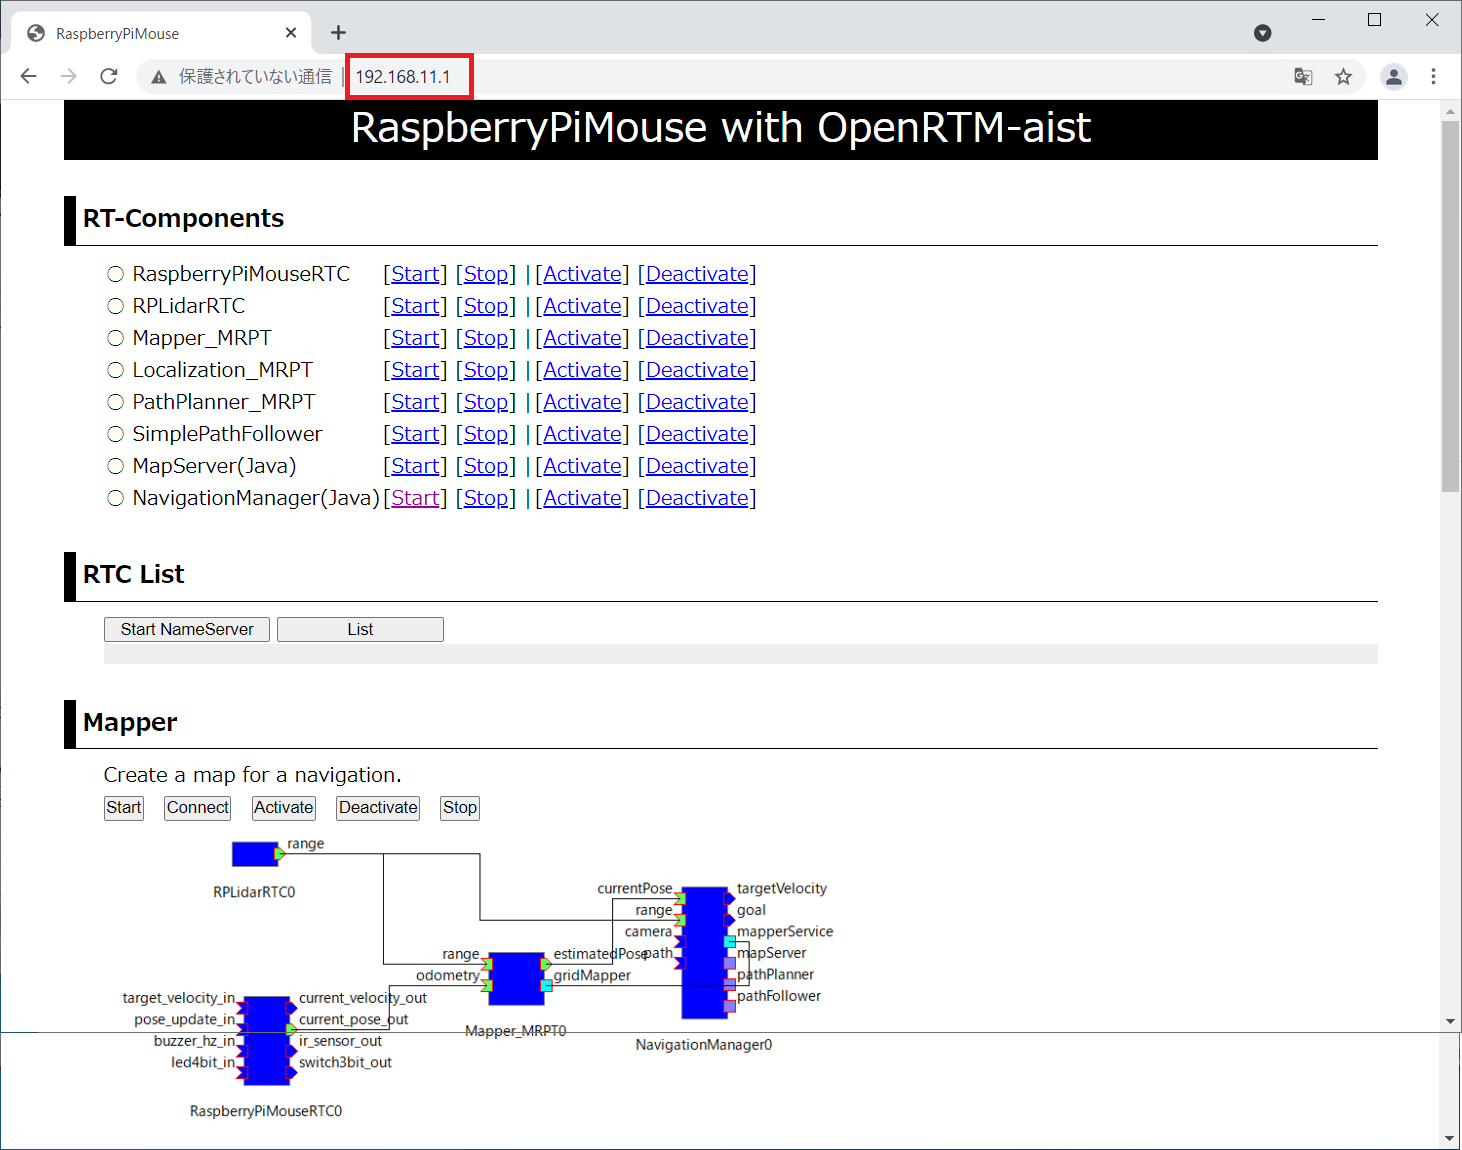
The RaspberryPiMouse with OpenRTM-aist screen will appear.
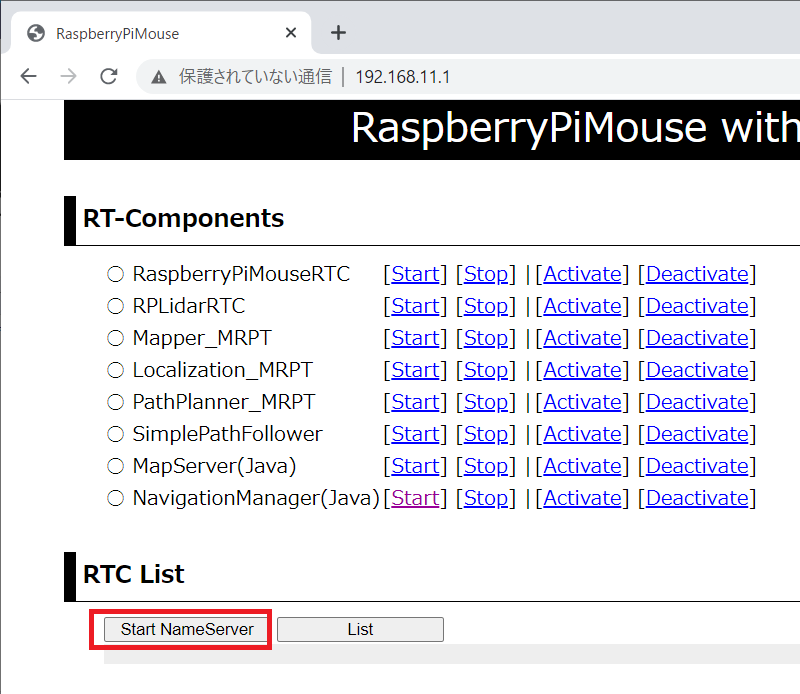
First, click the Start NameServer button to start the Name Server.
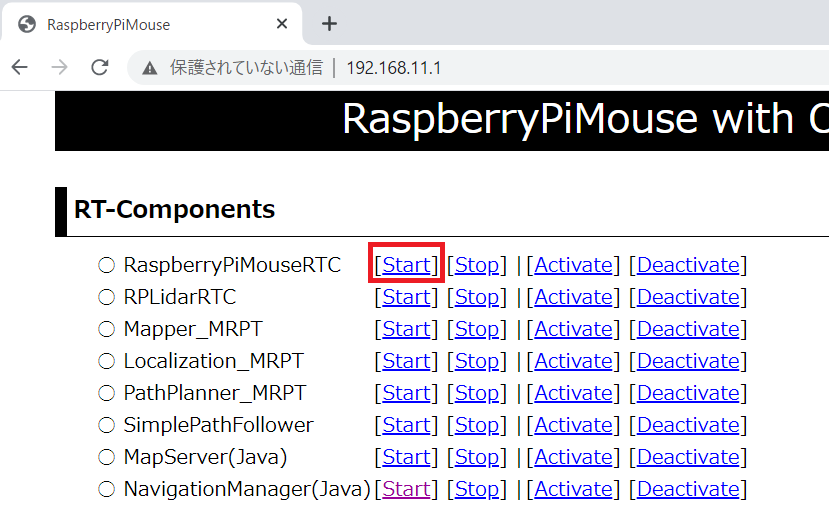
Next, click Start for RaspberryPiMouseRTC.
If the original page is not displayed again automatically, click Back to the top page.
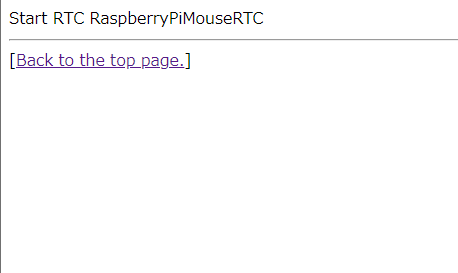
This completes the startup procedure.
Adding the Name Server
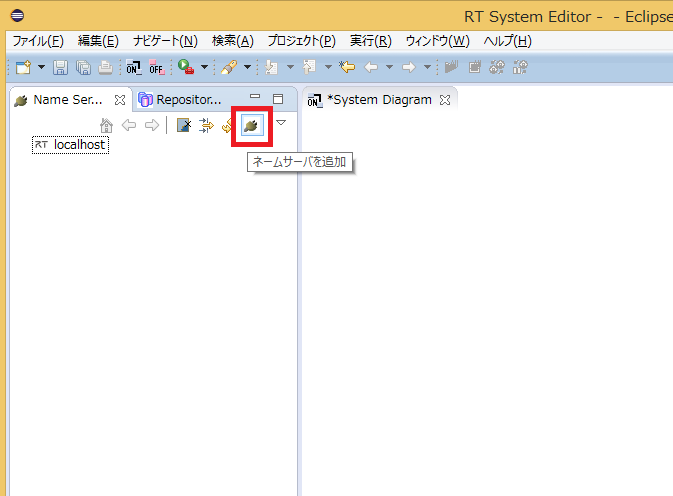
Next, use the [Add Name Server] button in RT System Editor to add 192.168.11.1.
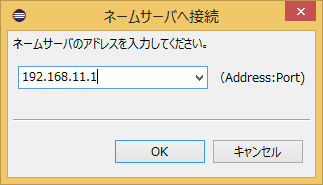
The following two RTCs will then appear.
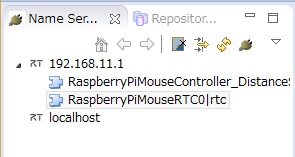
RaspberryPiMouseRTC is an RT component for controlling the Raspberry Pi Mouse developed by the Robot System Design Laboratory of Meijo University.
Connecting the Ports
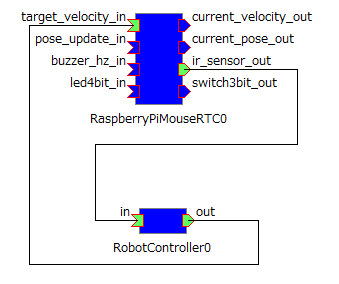
In RT System Editor, connect RaspberryPiMouseRTC and RobotController as shown below.
Turning On the Motor Power
Before operating the robot, turn on the motor power switch.
When the motors are not needed, turn off the motor power whenever possible.
Activation
After activating the RTCs, you will be able to control the Raspberry Pi Mouse.
Summary
In this tutorial, you learned:
- How to set up a development environment for OpenRTM-aist, Python, and RaspberryPiMouseSimulator on Ubuntu.
- How to generate a RobotController RTC using RTCBuilder.
- How to define Data Ports and Configuration parameters for robot control.
- How to edit the generated Python source code and implement RTC activity processing.
- How to build an RTC that outputs target velocity and stops automatically based on sensor values.
- How to start NameService, RobotController, and RaspberryPiMouseSimulator.
- How to connect and activate RTCs in RTSystemEditor.
- How to verify robot control using configuration sliders in the simulator.
- How to connect to a Raspberry Pi Mouse access point and operate an actual robot.
- How to start RaspberryPiMouseRTC and register it with a Name Server.
By completing this tutorial, you have learned how to create, configure, and operate a Python-based RobotController RTC for the Raspberry Pi Mouse on Ubuntu, and how to verify its operation both in simulation and on actual hardware.